
Reliable GPS-Free Vehicle Localization Framework for Next-Generation V2X Systems
[2023 – 2026]
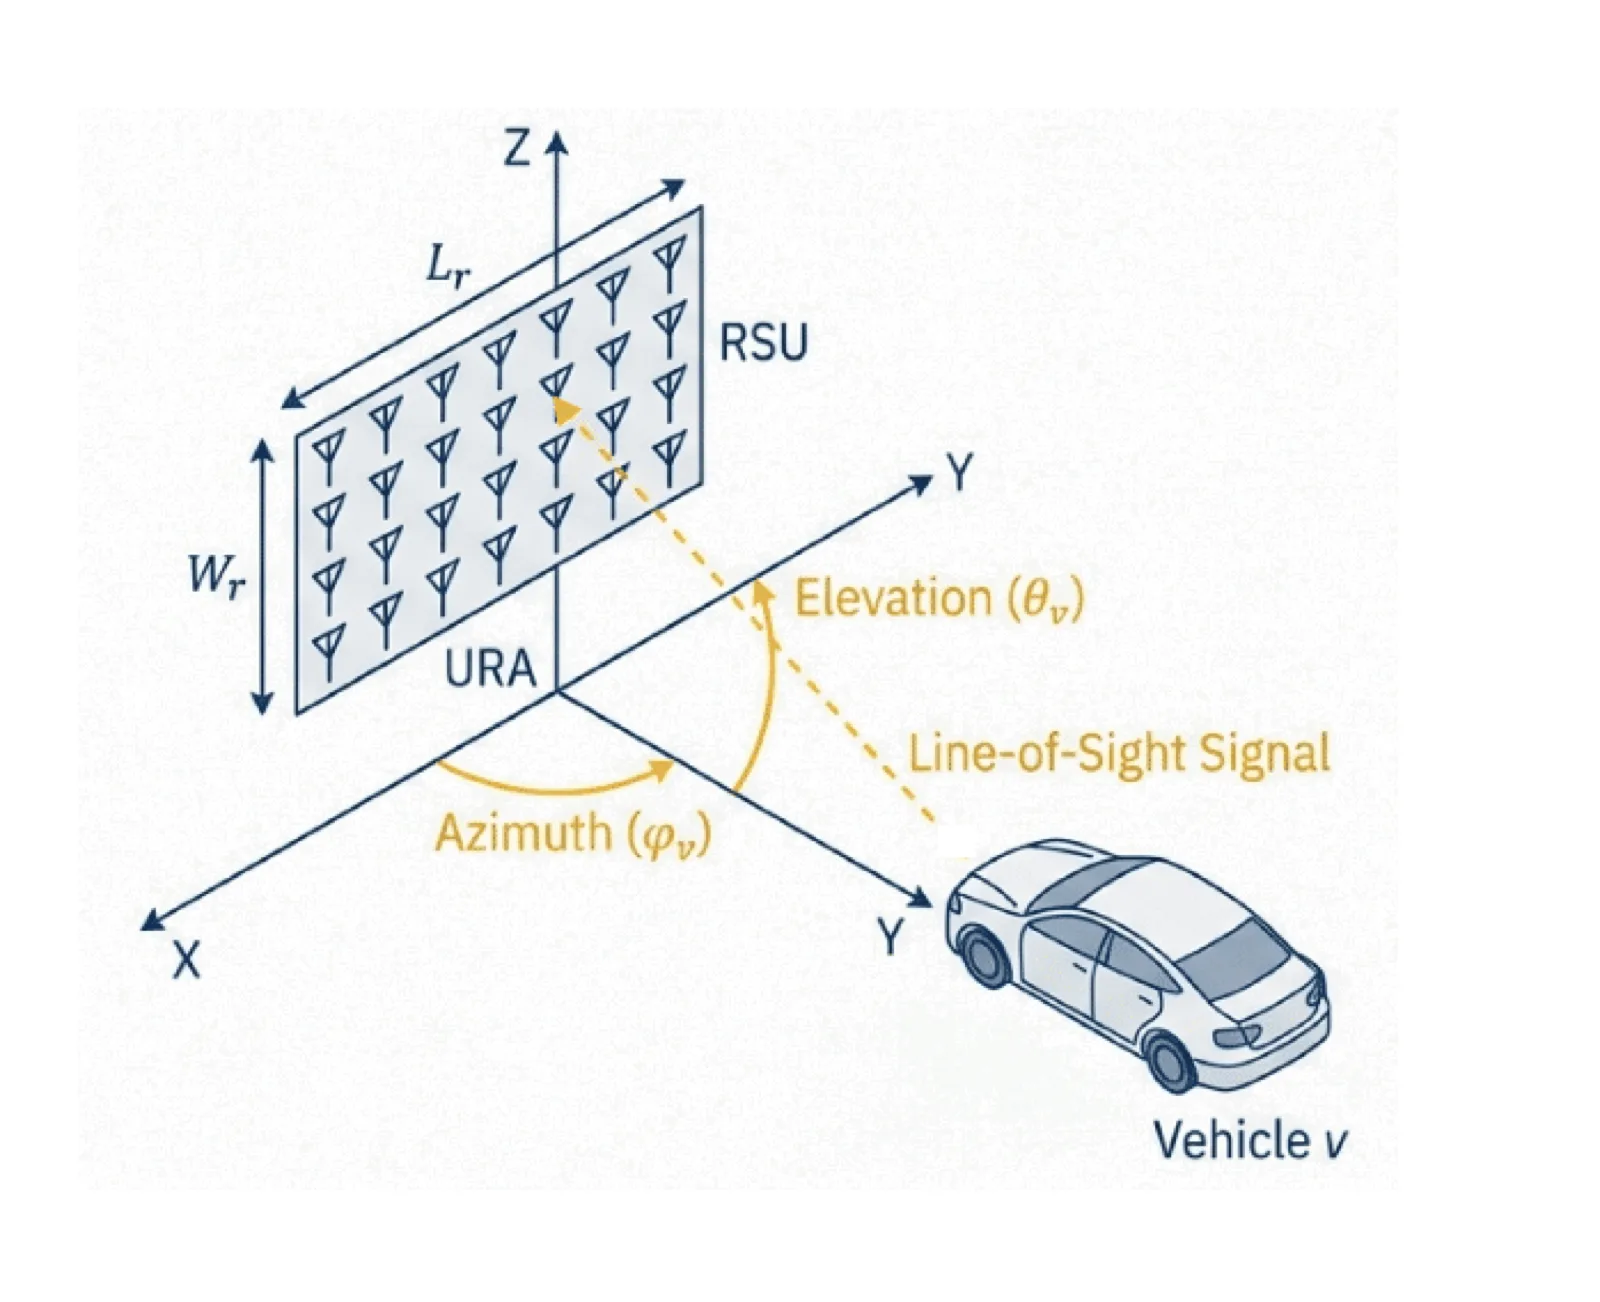
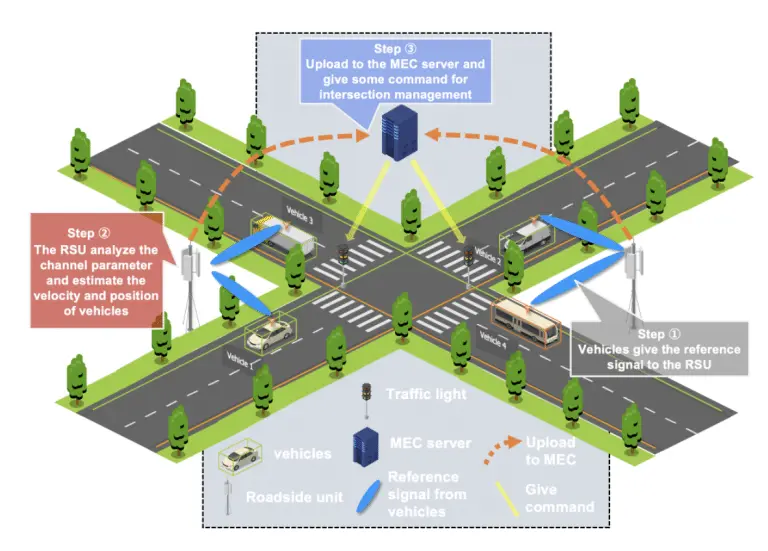
As autonomous driving and intelligent transportation systems (ITS) rapidly evolve, accurate vehicle localization has become a fundamental pillar for cooperative mobility and Vehicle-to-Everything (V2X) communications. While traditional GPS provides adequate positioning in open areas, its reliability drastically degrades in urban canyons, tunnels, and other non-line-of-sight (NLoS) environments. To address these limitations, our research project proposes a unified, GPS-free vehicular localization framework that leverages the rich physical-layer information of Beyond 5G/6G wireless communication channels. By integrating sensing and communication, this scalable infrastructure-assisted solution maintains high precision across blockage, high-mobility, and dense multi-user conditions.
For line-of-sight (LoS) environments, the project introduces a continuous tracking architecture based on millimeter-wave (mmWave) multi-antenna systems. We developed an adaptive, low-complexity 2D-MUSIC algorithm that efficiently extracts highly precise Direction-of-Arrival (DoA) and Time-of-Arrival (ToA) information. To overcome the instantaneous nature of geometric estimates, these spatial parameters are organically fused with vehicle motion dynamics using an Unscented Kalman Filter (UKF). This tightly coupled MUSIC-UKF approach effectively mitigates measurement noise and error accumulation, enabling stable, real-time trajectory and velocity estimation that is highly adaptable to complex road geometries like curves and intersections.
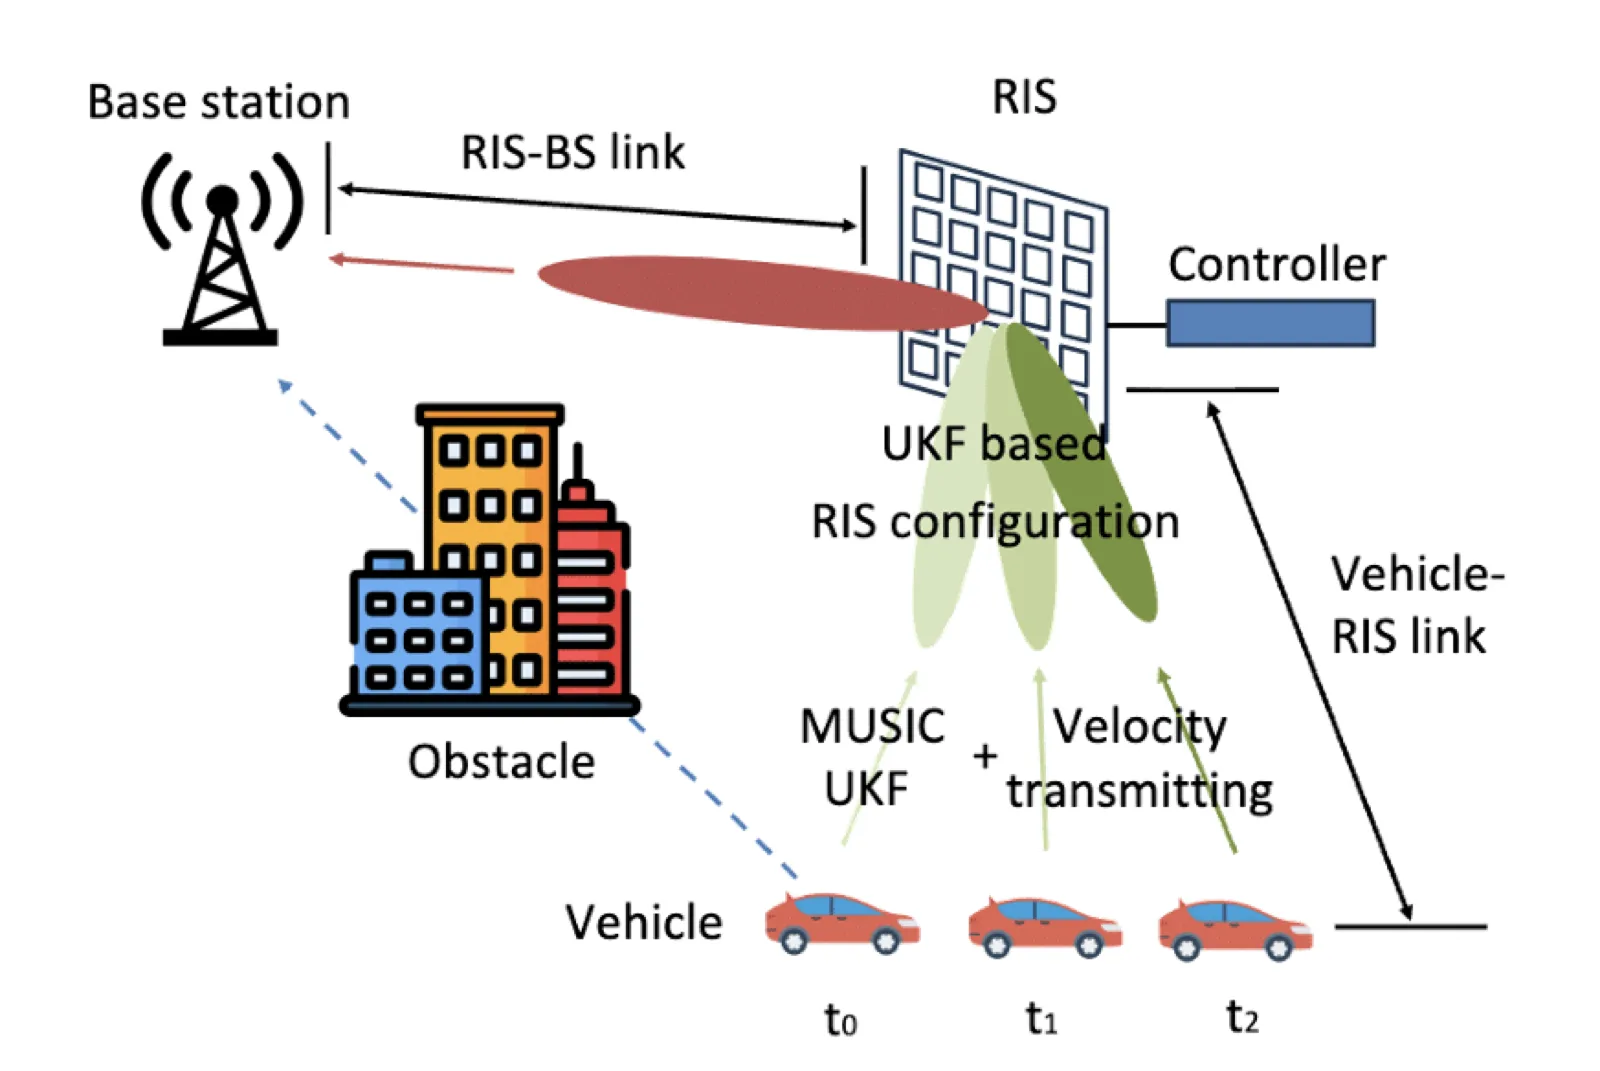
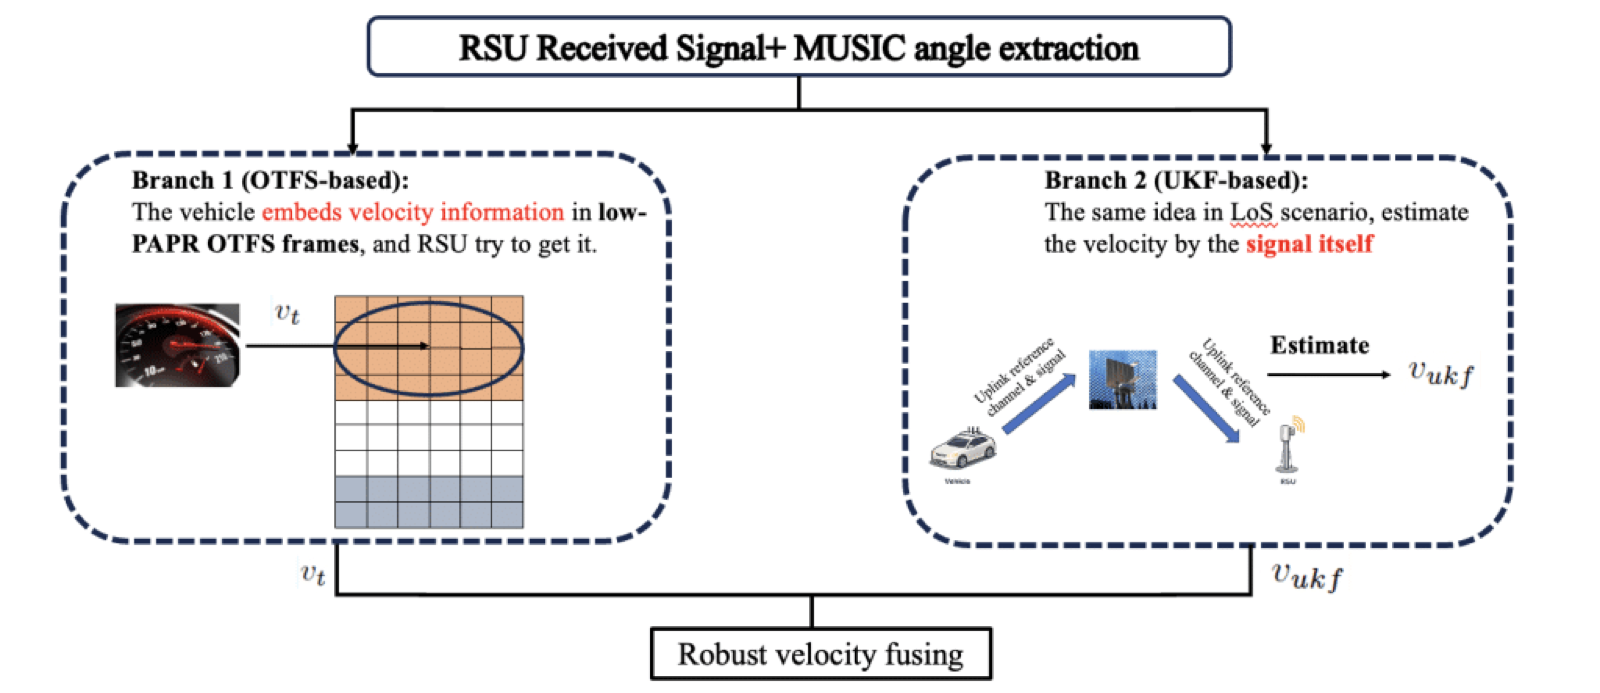
When direct LoS paths are obstructed, angle-based localization conventionally fails. To conquer this challenge, the framework transitions to an advanced sensing strategy integrating Reconfigurable Intelligent Surfaces (RIS) and Orthogonal Time Frequency Space (OTFS) modulation. The strategically deployed RIS reconstructs controllable virtual propagation paths around obstacles, restoring channel observability. Concurrently, the OTFS modulation, enhanced by a novel low Peak-to-Average Power Ratio (PAPR) pilot design, expertly resolves severe Doppler shifts and multipath fading typical of high-speed vehicular mobility. A dual-branch velocity estimation method utilizing the UKF further guarantees tracking resilience under these harsh NLoS conditions.
Finally, to ensure scalability for dense, real-world traffic scenarios, the framework is extended to support multi-user coexistence. It features an interference-aware iterative successive interference cancellation (SIC) scheme based on a page-style frame structure to efficiently separate overlapping user signals. Additionally, it employs an adaptive DoA estimation mechanism that dynamically selects the optimal processing mode—switching between Root-MUSIC for low-noise conditions and Forward-Backward Spatial Smoothing (FBSS) for high-interference regimes. Ultimately, this comprehensive research bridges classical array-signal processing with cutting-edge waveform design, laying a robust and reliable foundation for the cooperative perception required by future autonomous mobility networks.
Publication
- Reliable GPS-Free Vehicle Localization for V2X Systems: A Study across Blockage, High-Mobility, and Multi-User Conditions
Hu, Dou. Ph.D Thesis, The University of Tokyo, 2026 [PhD Thesis]BibTeX - Robust Vehicle Localization Based on Adaptive DOA Estimation and UKF under Varying Interference Conditions
Hu, Dou, Lin, Pengfei, Tsukada, Manabu. IEEE Consumer Communications & Networking Conference (CCNC2026), Poster, 2026 [Miscellaneous]BibTeX - DoA Estimation and Kalman Filter based Multi-Antenna System for Vehicle Position in mmWave Network
Hu, Dou, Nakazato, Jin, Ehsan, Javanmardi, Maruta, Kazuki, Dinis, Rui, Tsukada, Manabu. IEEE Open Journal of Vehicular Technology, vol. 6, pp. 2761-2775, 2025, ISSN: 2644-1330 [Journal Article]BibTeX - OTFS Based RIS-assisted vehicle positioning and tracking in V2X scenario
Hu, Dou, Nakazato, Jin, Maruta, Kazuki, Dinis, Rui, Aghda, Omid Abbassi, and Manabu Tsukada,. IEEE Transactions on Communications, vol. 73, iss. 11, pp. 10676-10691, 2025, ISSN: 0090-6778 [Journal Article]BibTeX - A Low PAPR Layered Multi-User OTFS Modulation
Hu, Dou, Nakazato, Jin, Maruta, Kazuki, Aghda, Omid Abbassi, Dinis, Rui, Tsukada, Manabu. AI-Driven Connectivity for Vehicular and Wireless Networks in VTC2025-Spring, Oslo, Norway, 2025, (IEEE VTS Tokyo/Japan Chapter 2025 Young Researcher’s Encouragement Award) [Workshop]BibTeX - A Research of Kalman Filter enabled Beam Tracking for Multiple Vehicles
Hu, Dou, Nakazato, Jin, Javanmardi, Ehsan, Asad, Muhammad, Kazuki, Maruta, Tsukada, Manabu. ASPIRE Workshop 2024 in conjunction with the IEICE General Conference, Hiroshima, Japan, 2024, ISBN: 2188-5079 [Workshop]BibTeX - Extended Kalman filter based beam tracking for vehicle position and velocity estimation under intersection scenario
Hu, Dou, Nakazato, Jin, Javanmardi, Ehsan, Asad, Muhammad, Tsukada, Manabu, Maruta, Kazuki. 革新的無線通信技術に関する横断型研究会(MIKA), 沖縄県, 2023 [Conference]BibTeX - An Extended Kalman Filter Enabled Beam Tracking Framework in Intersection Management
Hu, Dou, Nakazato, Jin, Javanmardi, Ehsan, Asad, Muhammad, Tsukada, Manabu. European Conference on Networks and Communications (EuCNC) & 6G Summit Poster, 2023 [Miscellaneous]BibTeX