
Connected Intelligence, Expanded Reality
Tsukada Laboratory, founded at the University of Tokyo's Graduate School of Information Science and Technology, Department of Creative Informatics, researches computer networks and cyber-physical systems. Our work spans cooperative autonomous driving, mixed reality, next-generation communications, and immersive media.
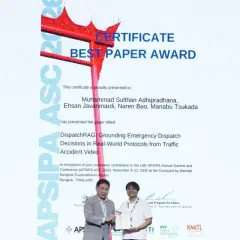
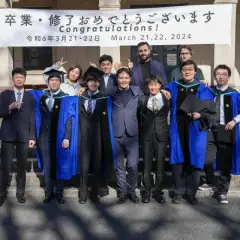
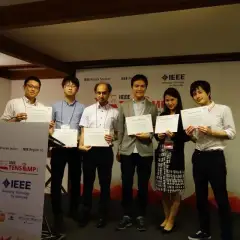
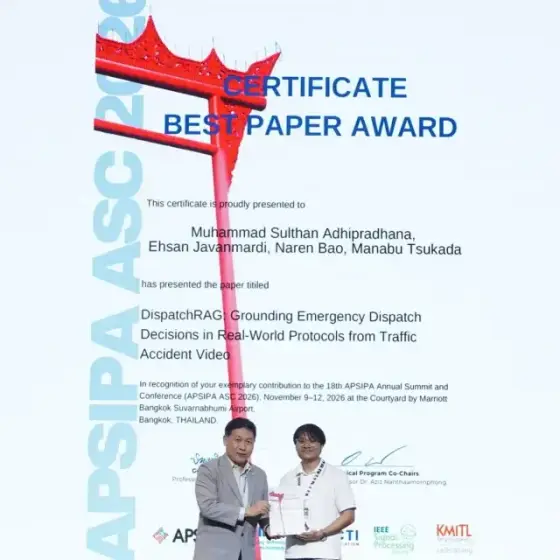 Huge congrats to Adhi (Muhammad Sulthan
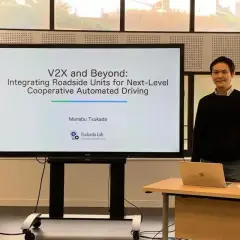
 We were delighted to welcome Prof.
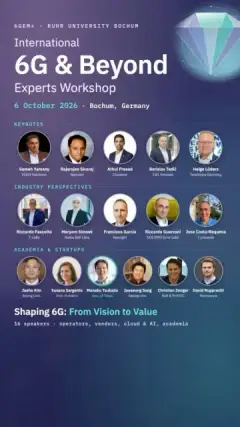
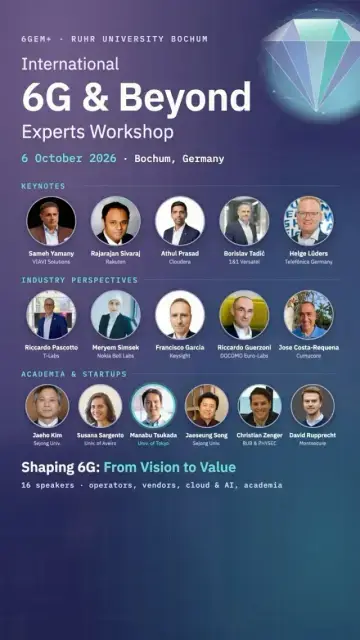 6G & Beyond in Bochum! On
 Paris leg of our European tour!On Oct 2
 A day of research, discovery, and great
 Research, shared curiosity, and new connections in
 Four days at IEEE ITSC 2026 in Naples!
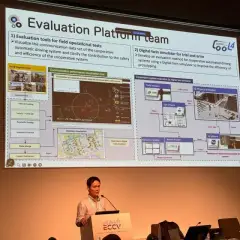
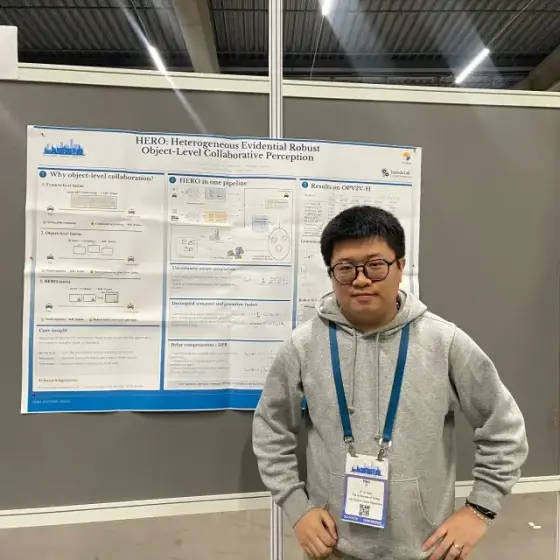 ECCV 2026 in Malmö! Our lab presented HERO:
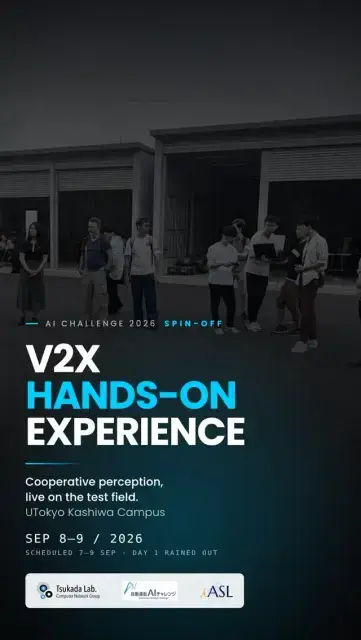 Real signals. Real crosswalks. Real rain.
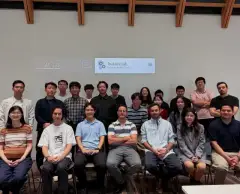
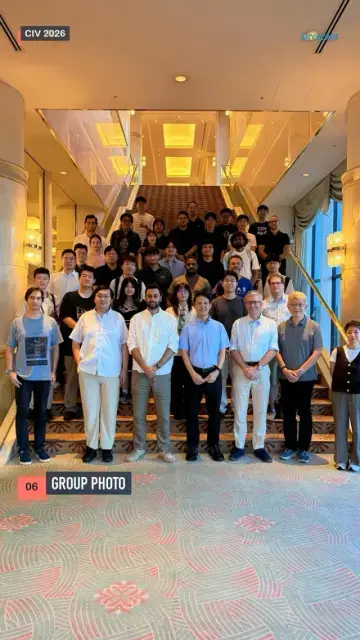 That’s a wrap on CIV Summer School 2026
Latest news
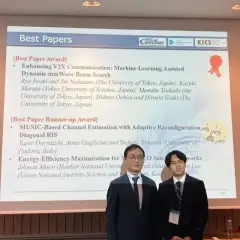
- Nov 14, 2026AwardConference reportBest Paper Award at APSIPA ASC 2026 in Bangkok
- Nov 12, 2026EventNewsDOICT-IndSoc 2027 Call for Papers in IEEE International Conference on Computer Communications (INFOCOM), May 24, 2027
- Oct 21, 2026Conference reportTalkInvited Talk at the International 6G & Beyond Experts Workshop in Bochum: Cooperative End-to-End Automated Driving as a 6G Service
- Sep 23, 2026Conference reportITSIEEE ITSC 2026 in Naples: Three Papers, a DriveX Keynote, and a W19 Invited Talk
- Sep 4, 2026EventTalkCIV Summer School 2026 in Miyazaki: Lectures, Data Hackathon, and the First Edition in Asia
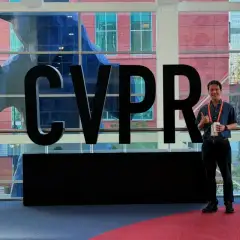
- Jun 9, 2026Conference reportITSKeynote Talk at the MEIS Workshop @ CVPR 2026
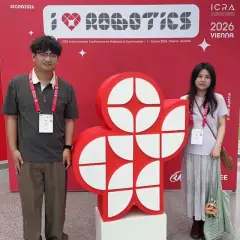
- Jun 9, 2026Conference reportITSIEEE ICRA 2026: Interactive Posters, International Collaborations, and Robot Parade
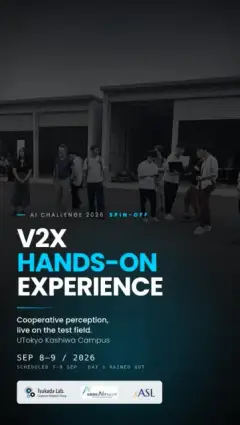
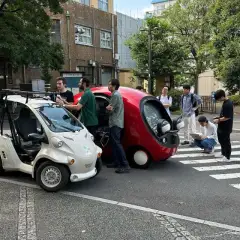
- Jun 5, 2026UncategorizedAI Challenge 2026 Spin-off — V2X Autonomous Driving Hands-on at Kashiwa Campus
Research highlights
Our laboratory drives cross-disciplinary projects spanning autonomous driving, mixed reality, next-generation communications, and digital twins. Each project integrates fundamental research with real-world implementation, delivering outcomes through field trials and international standardization efforts. Our current focus areas include the following:
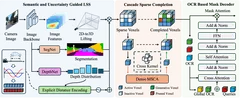
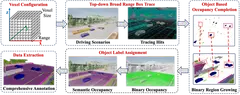
Collaborative 3D Semantic Occupancy Prediction for V2X-Enabled Autonomous Driving
Building an open synthetic benchmark and reference baselines for V2X…
Trajectory Planning for 6G Next-Generation UAVs/AMRs
Unmanned Aerial Vehicles (UAVs) and Autonomous Mobile Robots (AMRs)…
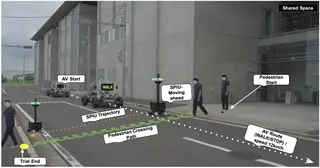
Smart Pole Interaction Unit (SPIU): Infrastructure-Side Communication for Pedestrian-AV Interaction in Shared Spaces
Investigating the Smart Pole Interaction Unit (SPIU) as an…
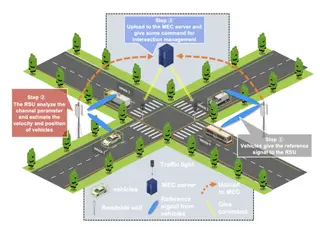
Reliable GPS-Free Vehicle Localization Framework for Next-Generation V2X Systems
Developing a robust, channel-adaptive vehicular localization and…
4D Path Planning, World Models, Reinforcement Learning, and VLM/VLA Integration for Autonomous Drones
This project seeks to establish a scientifically framework for…
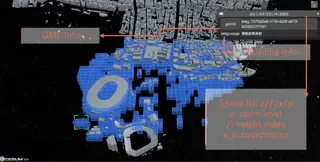
Spatial ID as a Scalable Spatial Index for Urban Digital Twins and Spatial Computing
Investigating Spatial ID as a standardized, multi-resolution spatial…
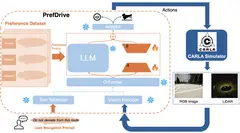
Multi-PrefDrive: Advancing LLM-Based Autonomous Driving via Multi-Preference Learning
Research on developing safer and more human-like autonomous driving…
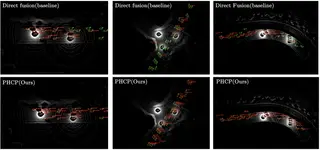
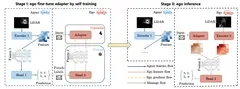
Progressive Heterogeneous Collaborative Perception (PHCP): A Communication Technology for Autonomous Vehicles to Adapt and Connect on the Fly
A novel framework enabling collaborative perception among vehicles…
Extending Autoware for Cooperative Driving: Integrating Perception, Planning, and Coordination
We extended the open-source Autoware platform with cooperative…
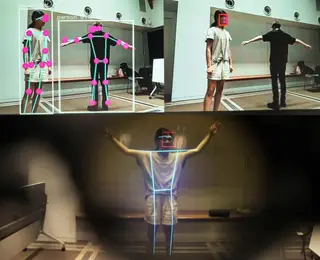
Vision AI Co-Processing for Dynamic Context Awareness in Mixed Reality
Real-time offloading of semantic perception tasks from MR headsets to…
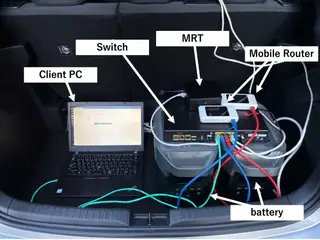
Designing a Multipath Redundancy Communication Framework for Reliable Real-Time Streaming over 5G
Developing a multipath framework to improve real-time media quality…
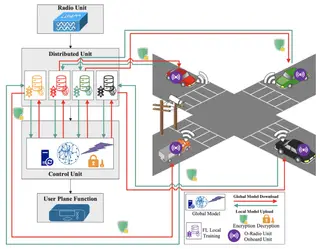
Federated Learning and Edge AI for Intelligent and Secure Connected Vehicle Networks
Building a federated learning-based architecture for efficient and…
Design of Digital Twin-Based Infrastructure for 3D Audio Spatialization
Building a digital twin platform that fuses large-scale geometry…
Integrated Spatial Information Platform through BIM-Based Digital Twin
Developing a next-generation BIM-based digital twin that fuses…
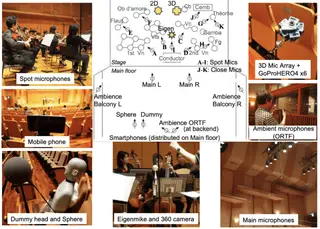
SDM Ontology: A Descriptive Foundation for Spatio-Temporal Media Experiences
A metadata framework to describe and utilize media content with…
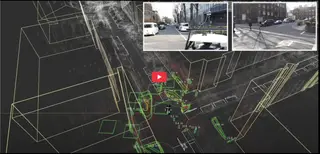
Next-Generation Autonomous Driving Support Infrastructure through Roadside Perception Units (RSPUs)
Designing and deploying networked RSPUs to enable…
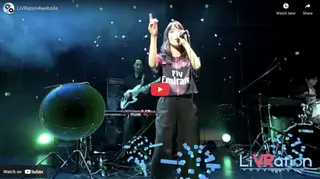
Software Defined Media and LiVRation: Building Interactive Object-Based Viewing Spaces
A programmable media platform enabling immersive and interactive live…
Publications
Talks & awards
- Nov 14, 2026AwardBest Paper Award at APSIPA ASC 2026 in Bangkok
- Oct 21, 2026Conference reportInvited Talk at the International 6G & Beyond Experts Workshop in Bochum: Cooperative End-to-End Automated Driving as a 6G Service
- Sep 4, 2026EventCIV Summer School 2026 in Miyazaki: Lectures, Data Hackathon, and the First Edition in Asia
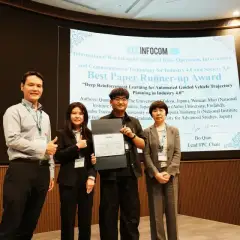
- May 19, 2026AwardIEEE INFOCOM 2026 Report: Local Arrangements Chair, DOICT-IndSoc Workshop Organization, and Best Paper Runner-up Award
- May 15, 2026AwardACM CHI 2026 Report: Paper Presentation and Honorable Mention Award
Software & data
The URT-Kashiwa Dataset (Unprotected Right Turn, Kashiwa…
open data2025
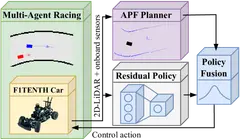
We’re thrilled to announce the publication of our research…
open source2023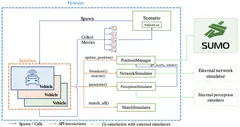
open source2023
A research team from the University of Tokyo’s Graduate…
open dataopen source2021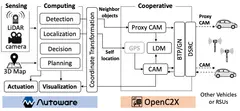
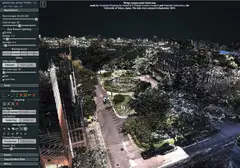
We published “UTokyo Hongo campus point cloud map“. The…
open data2020Videos
CIV Summer School 2026 in Miyazaki: Lectures, Data Hackathon, and the First Edition in Asia
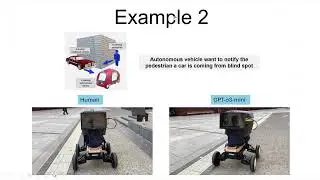
Exploring LLMs for Generating Communicational Actions of External Interfaces on Autonomous Vehicles
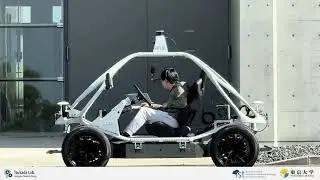
AI Challenge 2026 Spin-off — V2X Autonomous Driving Hands-on at Kashiwa Campus
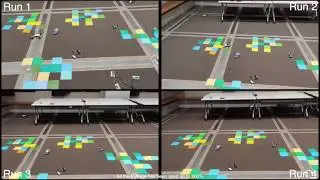
Trajectory Planning for UAV-Based Smart Farming Using Imitation-Based Triple Deep Q-Learning
Meet the team


We are looking for post-doctoral researchers, doctoral and master's students.