
Research
Collaborative 3D Semantic Occupancy Prediction for V2X-Enabled Autonomous Driving
Building an open synthetic benchmark and reference baselines for V2X cooperative 3D semantic occupancy prediction, so that connected vehicles and…
Trajectory Planning for 6G Next-Generation UAVs/AMRs
Unmanned Aerial Vehicles (UAVs) and Autonomous Mobile Robots (AMRs) are foundational platforms for 6G-era applications spanning aerial surveillance…
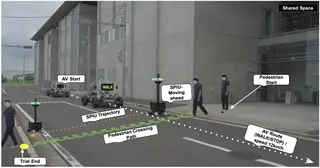
Smart Pole Interaction Unit (SPIU): Infrastructure-Side Communication for Pedestrian-AV Interaction in Shared Spaces
Investigating the Smart Pole Interaction Unit (SPIU) as an infrastructure-side interface that complements vehicle eHMI to reduce pedestrian…
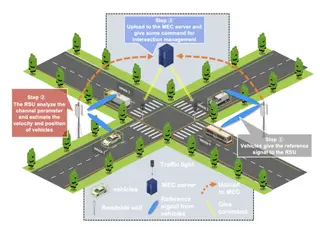
Reliable GPS-Free Vehicle Localization Framework for Next-Generation V2X Systems
Developing a robust, channel-adaptive vehicular localization and tracking system utilizing mmWave MIMO, RIS, and OTFS technologies for environments…
4D Path Planning, World Models, Reinforcement Learning, and VLM/VLA Integration for Autonomous Drones
This project seeks to establish a scientifically framework for Level-4 autonomous flight of unmanned aerial vehicles (UAVs). Unlike traditional…
Spatial ID as a Scalable Spatial Index for Urban Digital Twins and Spatial Computing
Investigating Spatial ID as a standardized, multi-resolution spatial indexing layer that enables interoperable urban data systems, real-time…
Multi-PrefDrive: Advancing LLM-Based Autonomous Driving via Multi-Preference Learning
Research on developing safer and more human-like autonomous driving systems using large language models that learn human driving preferences.
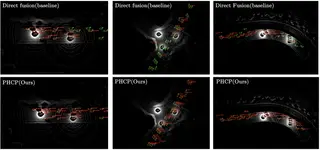
Progressive Heterogeneous Collaborative Perception (PHCP): A Communication Technology for Autonomous Vehicles to Adapt and Connect on the Fly
A novel framework enabling collaborative perception among vehicles with different models by adapting on-the-fly during inference.
Extending Autoware for Cooperative Driving: Integrating Perception, Planning, and Coordination
We extended the open-source Autoware platform with cooperative perception and maneuver coordination features, enabling next-generation…
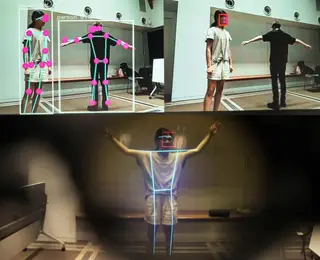
Vision AI Co-Processing for Dynamic Context Awareness in Mixed Reality
Real-time offloading of semantic perception tasks from MR headsets to edge AI accelerators, enabling scene-level understanding and interaction in…
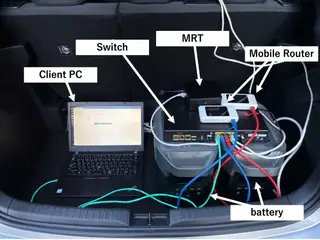
Designing a Multipath Redundancy Communication Framework for Reliable Real-Time Streaming over 5G
Developing a multipath framework to improve real-time media quality under fluctuating 5G network conditions by leveraging multiple mobile connections…
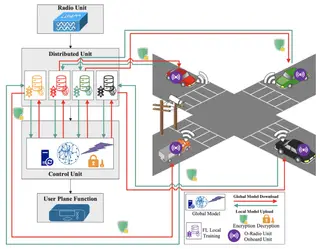
Federated Learning and Edge AI for Intelligent and Secure Connected Vehicle Networks
Building a federated learning-based architecture for efficient and secure communication and intelligence in connected autonomous vehicles.
Design of Digital Twin-Based Infrastructure for 3D Audio Spatialization
Building a digital twin platform that fuses large-scale geometry, precise positioning, and real-time acoustic simulation to enable responsive 3D…
Integrated Spatial Information Platform through BIM-Based Digital Twin
Developing a next-generation BIM-based digital twin that fuses building geometry, spatial acoustics, and semantic data for real-to-virtual…
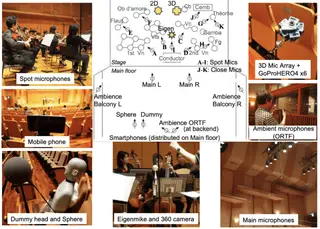
SDM Ontology: A Descriptive Foundation for Spatio-Temporal Media Experiences
A metadata framework to describe and utilize media content with spatial and temporal context, enabling interactive and reusable applications.
Next-Generation Autonomous Driving Support Infrastructure through Roadside Perception Units (RSPUs)
Designing and deploying networked RSPUs to enable infrastructure-driven cooperative perception for safe and efficient autonomous driving.
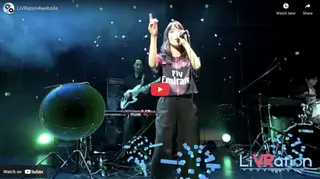
Software Defined Media and LiVRation: Building Interactive Object-Based Viewing Spaces
A programmable media platform enabling immersive and interactive live experiences through networked control of spatial audiovisual environments.