
Trajectory Planning for 6G Next-Generation UAVs/AMRs
[2024 – 2026]
Unmanned Aerial Vehicles (UAVs) and Autonomous Mobile Robots (AMRs) are foundational platforms for 6G-era applications spanning aerial surveillance, disaster response, warehouse logistics, and precision agriculture. Autonomous trajectory planning under interference, partial observability, energy constraints, and multi-agent coordination remains a central bottleneck.
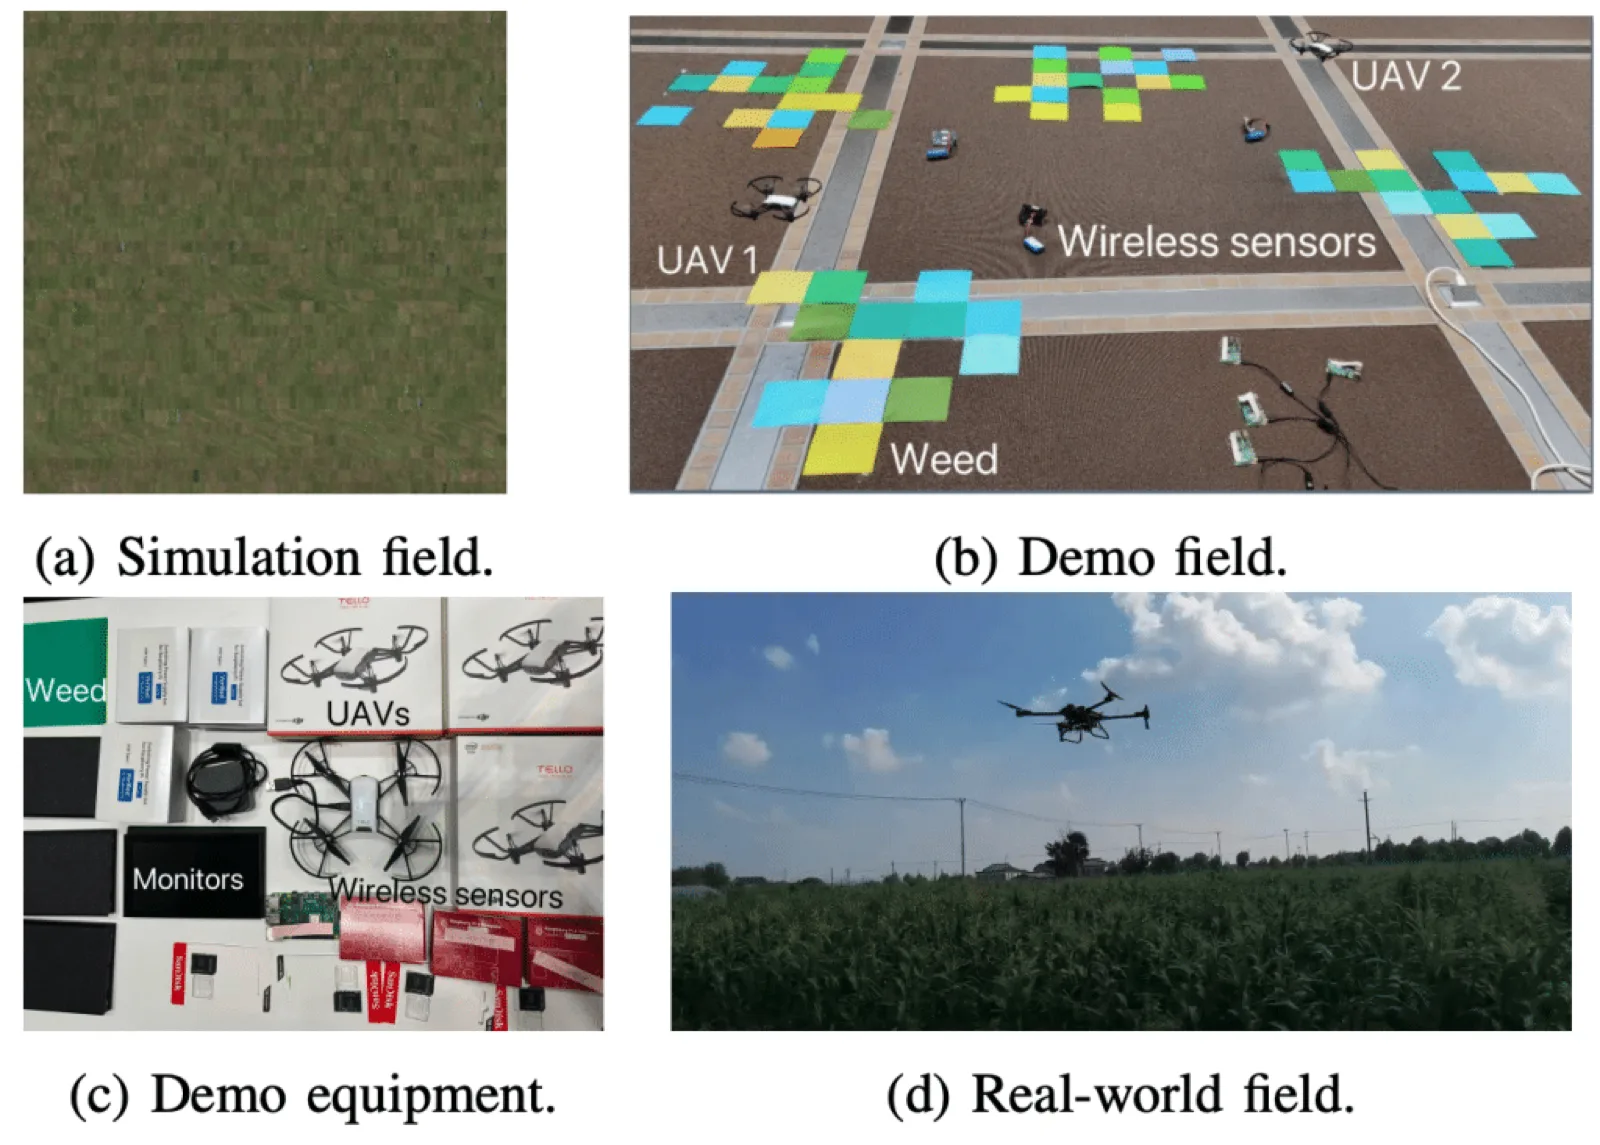
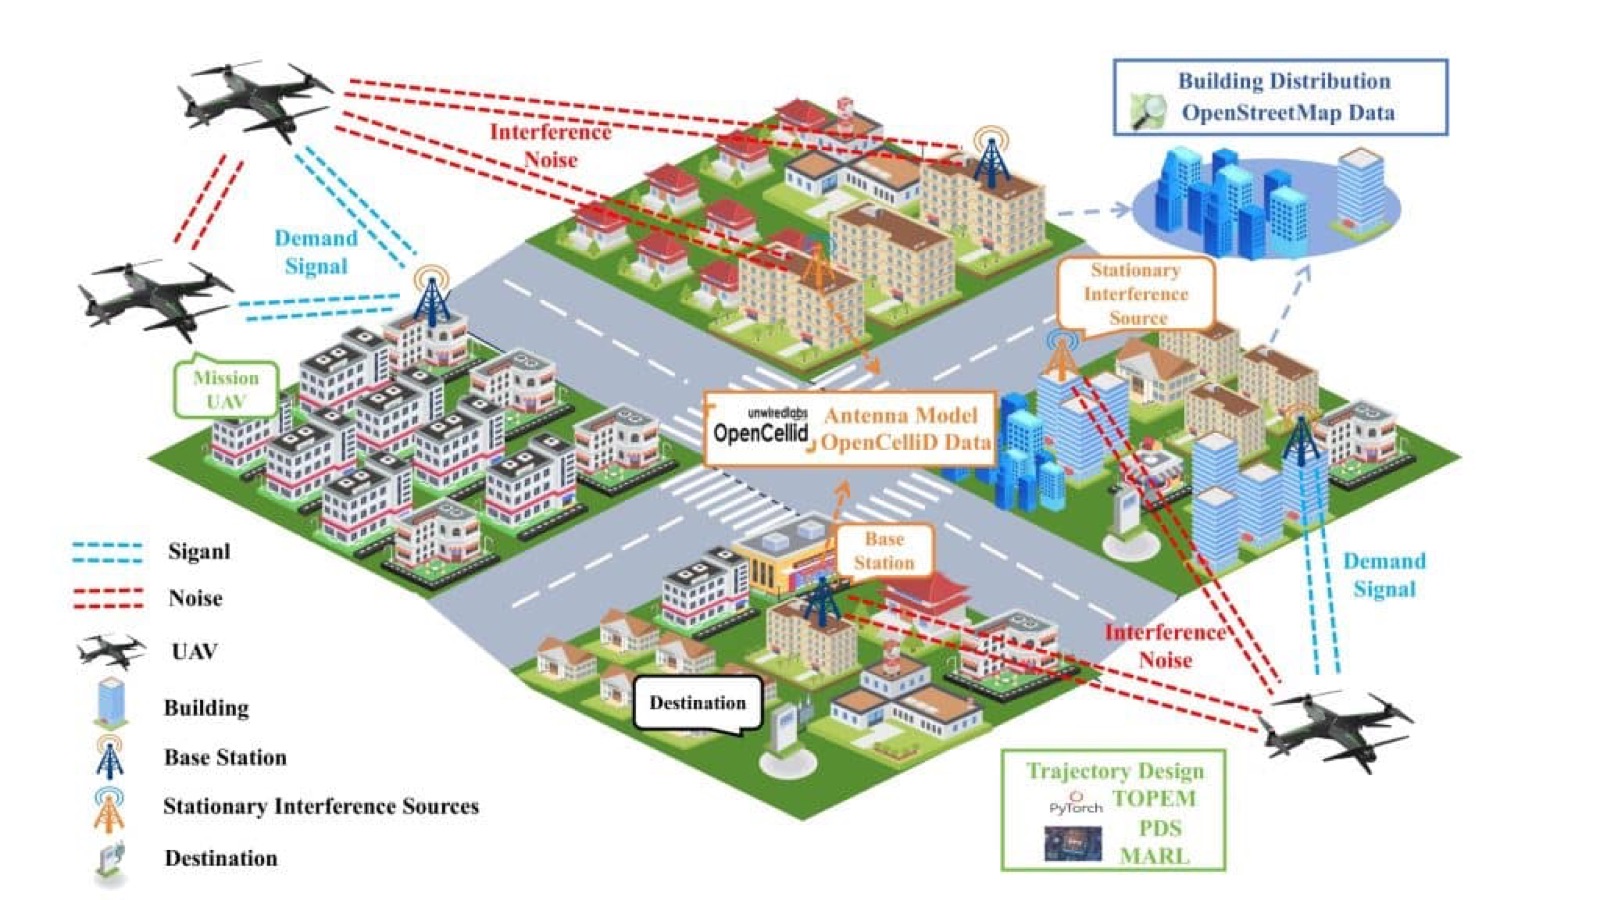
UAVs (drones) and AMRs (ground robots) are complementary autonomy platforms. UAVs offer access to hard-to-reach areas, reduced risk to human life, and rapid deployment, but face battery, payload, weather, and regulatory limits. AMRs deliver high endurance, payload, and flexibility on the factory floor at the cost of vertical reach, terrain limits, and integration effort. Both will be first-class endpoints in 6G networks.
This research presents an end-to-end planning framework with novel reinforcement-learning (RL) algorithms, together with a CARLA/AirSim simulation pipeline and a small physical testbed. The framework targets closed-loop evaluation, where planner outputs drive the agent and successive errors compound, and is guided by three properties: generality (transfer across sites and tasks), efficiency (sample- and inference-time), and customizability (swappable perception, dynamics, and objectives).
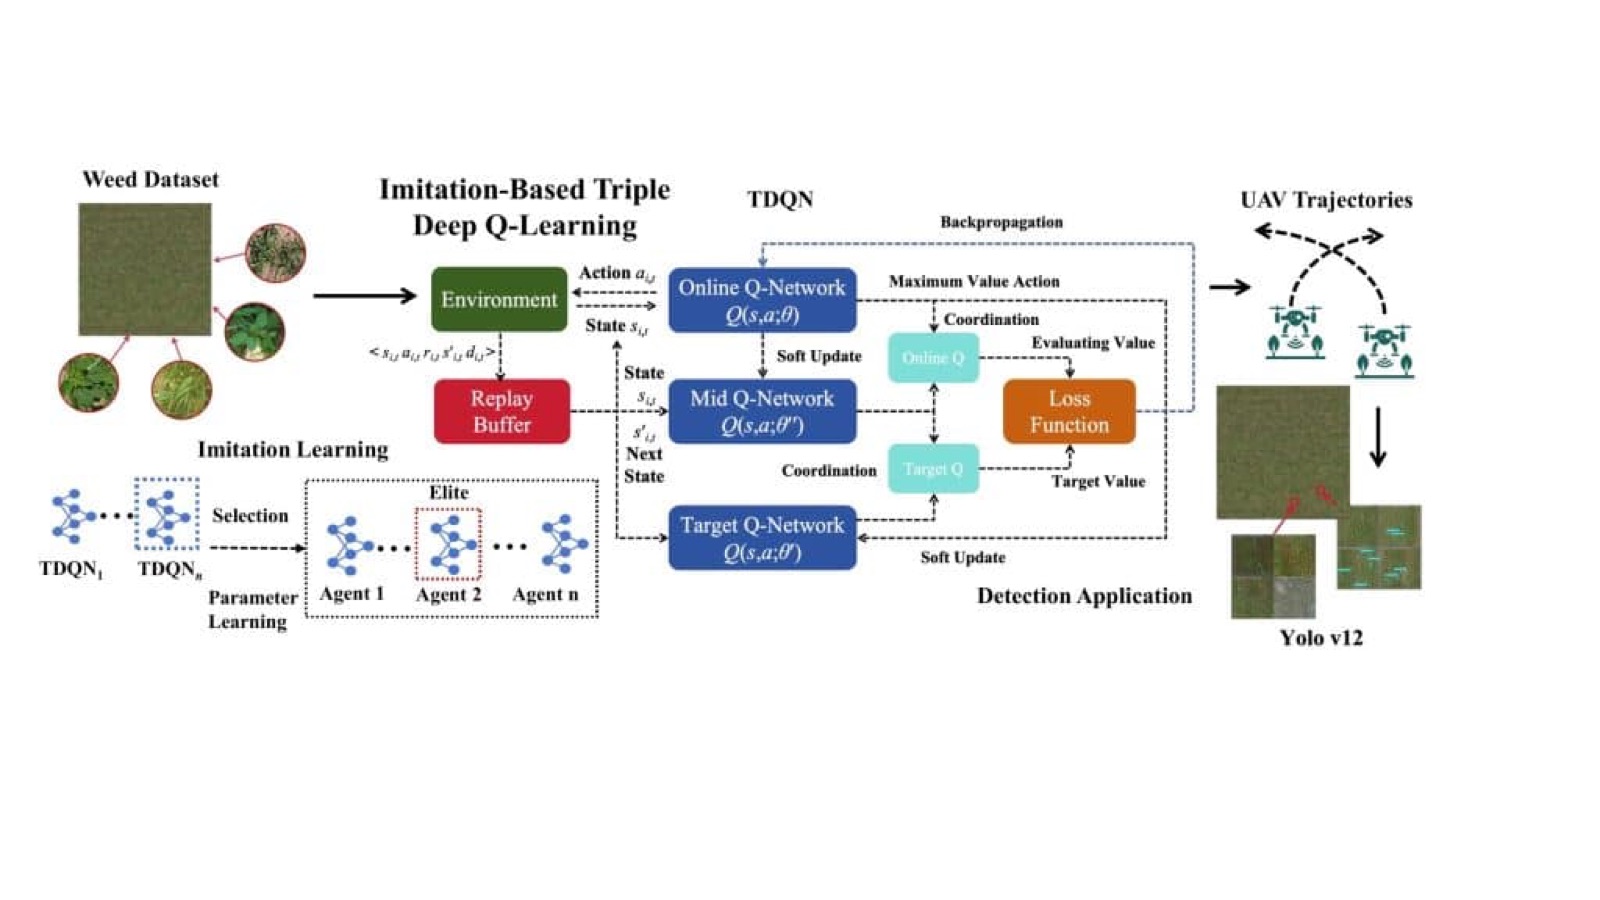
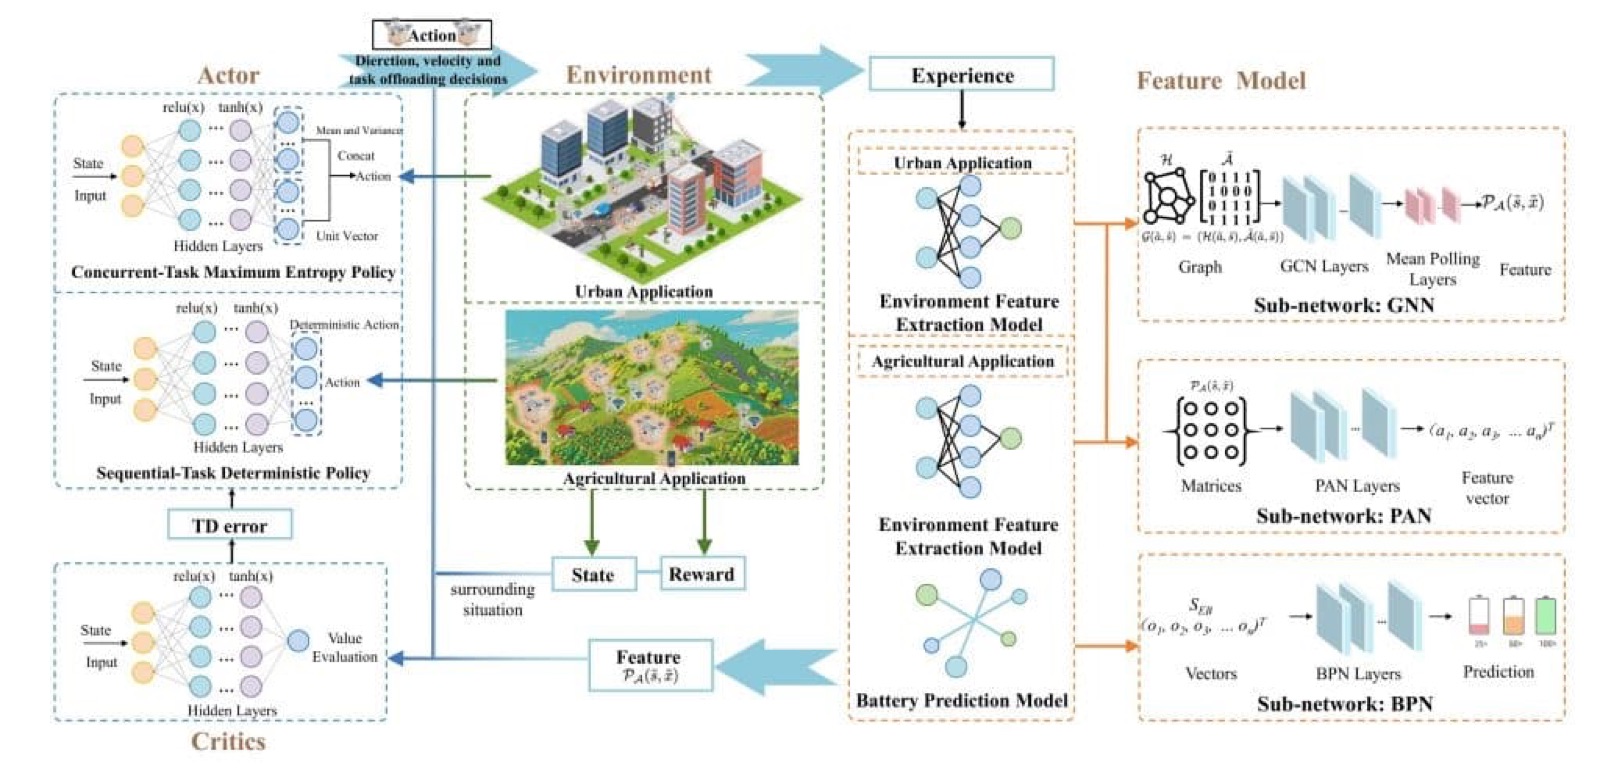
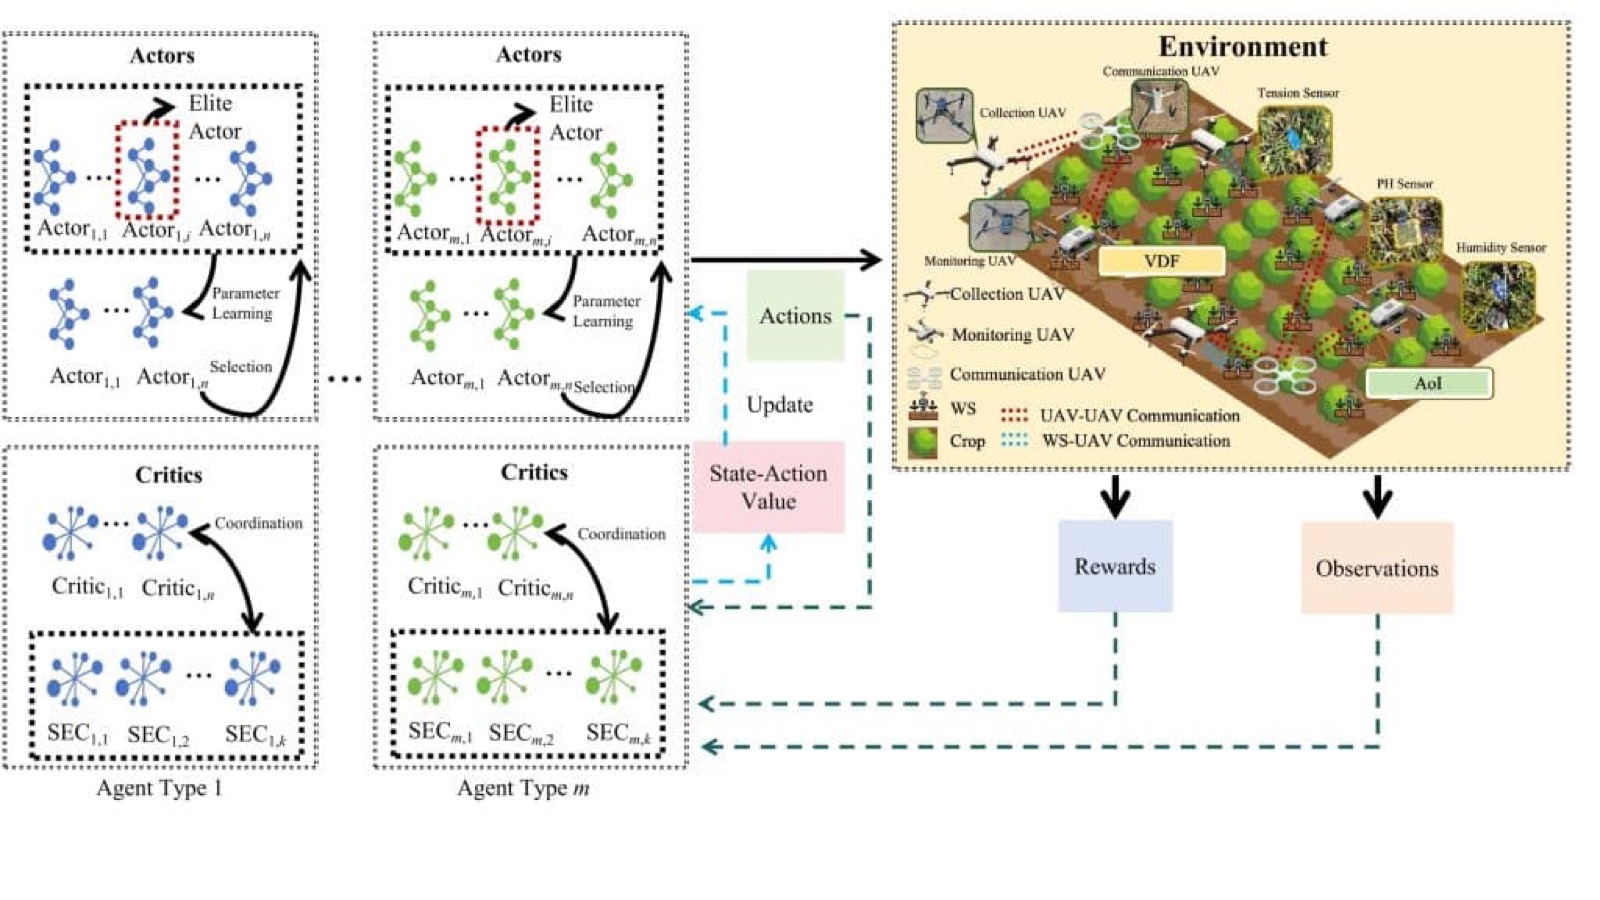
Four algorithms share a multi-agent RL skeleton and specialize it along different axes. UA-MARL (Uncertainty-Aware Multi-Agent RL) aims to increase sample efficiency. ITDQN (Imitation-based Triple Deep Q-Learning) is designed for balancing exploration and exploitation. FM-EAC (Feature Model-based Enhanced Actor-Critic) targets improving training efficiency and generalizability. Finally, EIA-SEC (Elite Imitation Actor-Shared Ensemble Critic) has the goal of improving training efficiency and customizability.
Two simulators support algorithm development: CARLA, an open-source autonomous-driving simulator with a modern rendering pipeline, pre-made urban maps, and simulated camera/LiDAR sensors controlled remotely over TCP — the natural target for AMR-side experiments; and AirSim, an Unreal-Engine-based simulator with platform-independent APIs widely used for UAV deep-learning and RL research. The physical testbed comprises four DJI Tello UAVs, four Raspberry-Pi controllers, and four ground AMRs, with additional cameras, IMUs, and LiDAR planned. The setup is designed to support human-in-the-loop experimentation in which operator interventions feed back into policy updates.
Publication
- Trajectory Planning for UAV-Based Smart Farming Using Imitation-Based Triple Deep Q-Learning
Zhou, Quanxi, Mao, Wencan, Coddou, Tomás Couso, Tsukada, Manabu, Yunling, Liu, Ji, Yusheng. IEEE International Conference on Robotics & Automation (ICRA 2026), Vienna, Austria, 2026 [Proceedings Article]BibTeX - Deep Reinforcement Learning for Automated Guided Vehicle Trajectory Planning in Industry 4.0
Zhou, Quanxi, Mao, Wencan, Xiao, Yu, Tsukada, Manabu, Ji, Yusheng. INFOCOM 2026 International Workshop on Fusion of Data, Operation, Information, and Communication Technology for Industry 4.0 and Society 5.0 (DOICT-IndSoc), 2026, (Best Paper Runner-up Award) [Workshop]BibTeX - A Feature-Aware Elite-Imitation MARL for Multi-UAV Trajectory Optimization in Mountain Terrain Detection
Zhou, Quanxi, Tao, Ye, Su, Qianxiao, Tsukada, Manabu. Drones, 2025 [Journal Article]BibTeX - Uncertainty-Aware Multi-Agent Reinforcement Learning for Anti-Interference Trajectory Planning of Cellular-Connected UAVs
Zhou, Quanxi, Mao, Wencan, Nakazato, Jin, Ji, Yusheng, Tsukada, Manabu. IEEE Transactions on Vehicular Technology, pp. 1 - 17, 2025, ISBN: 0018-9545 [Journal Article]BibTeX - Multi-Modal Trajectory Planning for Emergency-Oriented Air-Ground Collaborative Sensing and Communication
Liu, Yaxi, Zhou, Quanxi, Mao, Wencan, Li, Xulong, Huangfu, Wei, Tsukada, Manabu, Ji, Yusheng, Long, Keping. IEEE Transactions on Cognitive Communications and Networking, vol. 11, iss. 5, pp. 3094-3111, 2025, ISSN: 2332-7731 [Journal Article]BibTeX - Cellular Connected UAV Anti-Interference Path Planning Based on PDS-DDPG and TOPEM
Zhou, Quanxi, Wang, Yongjing, Shen, Ruiyu, Nakazato, Jin, Tsukada, Manabu, Guan, Zhenyu. IEEE Journal on Miniaturization for Air and Space Systems, 2024, ISSN: 2576-3164 [Journal Article]BibTeX